Recycled Plastic Pelletizer
One motor, two belts, one sensor — a pelletizer that turns waste 3D-printing filament into 3 mm pellets.
Summary
- What it is
- A single-motor pelletizer that turns waste 3D-printing filament into 3 mm pellets
- Role
- Mechanical design and drive ratio, CAD, ESP32 firmware and testing
- Team
- 5 (ES 1050 Design, Western)
- Dates
- Winter 2026
- Tools
- ESP32, C++, AccelStepper, A4988 stepper driver, IR beam-break sensor, GT2 timing belts (×2), Onshape
- Results
- Gear-drive prototype: fed a 1 m PLA strand autonomously at 3 mm/s, under 50 dB, 12 V input, 0.5 A idle draw; first pellets cut cleanly, then the cutter jammed. Final GT2 design: built, no measurements taken.
Problem
Turn waste 3D-printing filament into 3 mm pellets, with one motor doing both the feeding and the cutting.
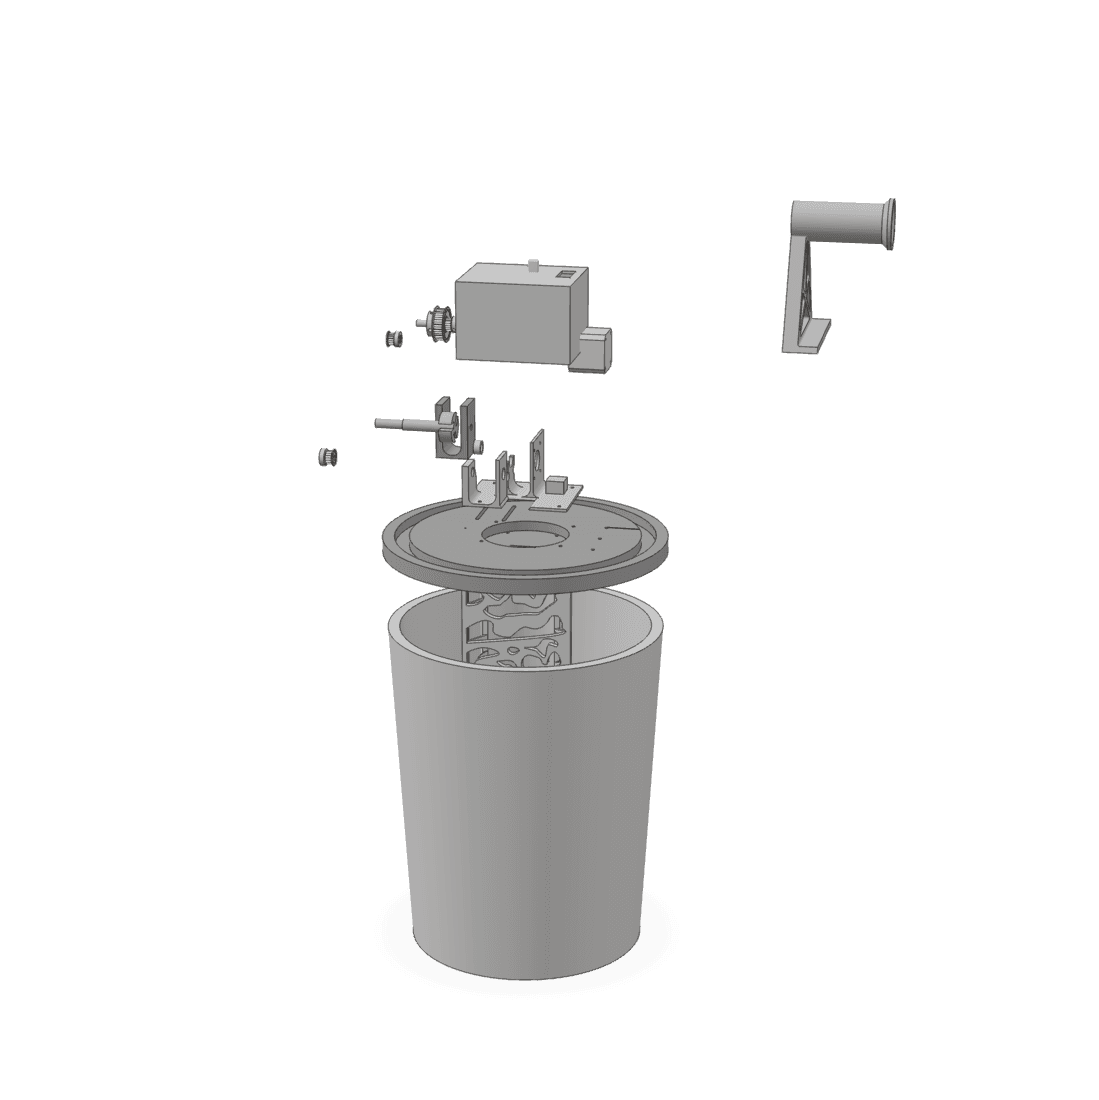
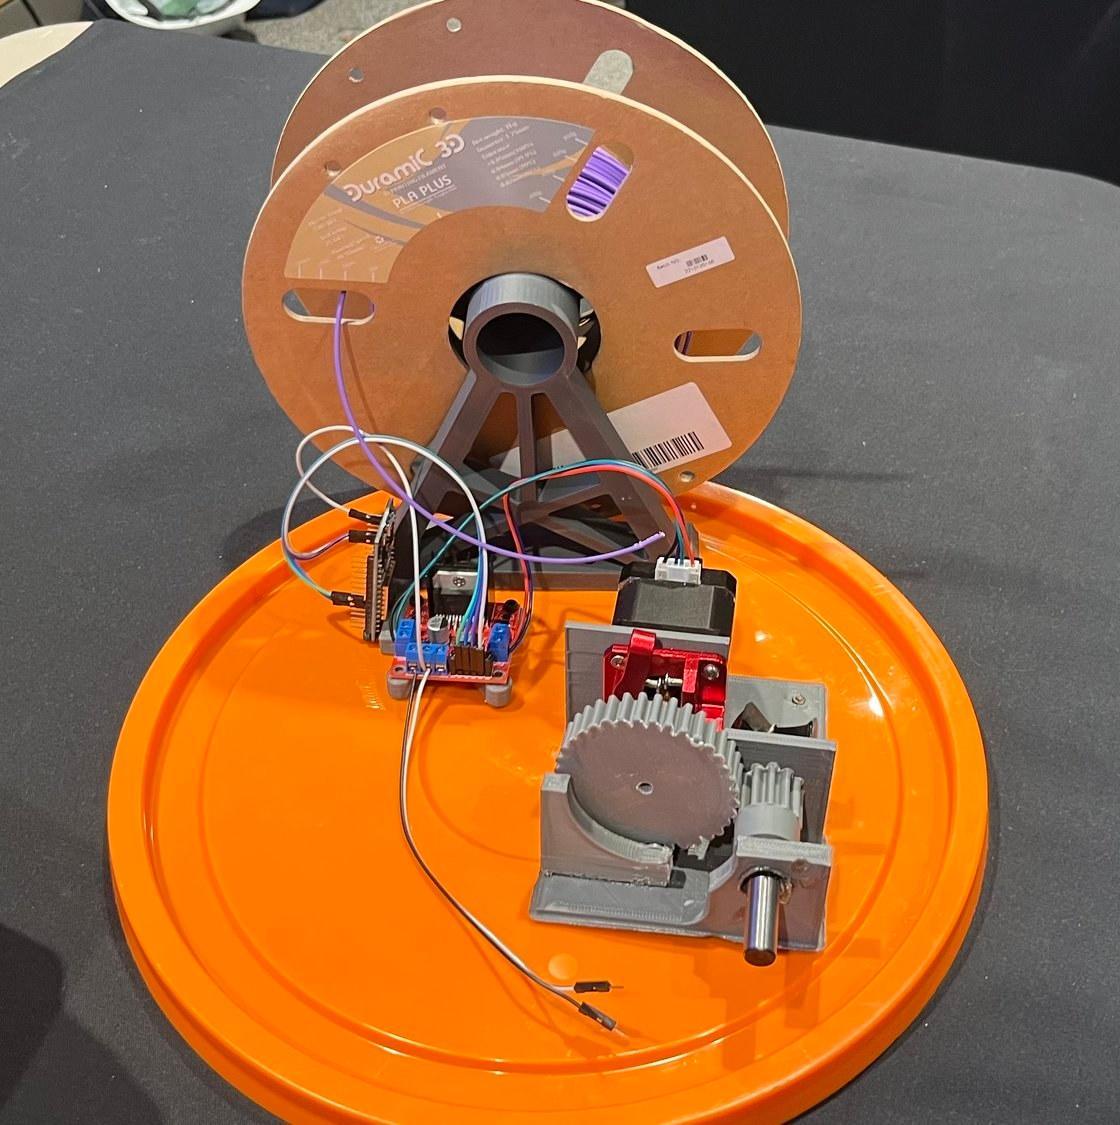
Early gear-drive prototype
What I built
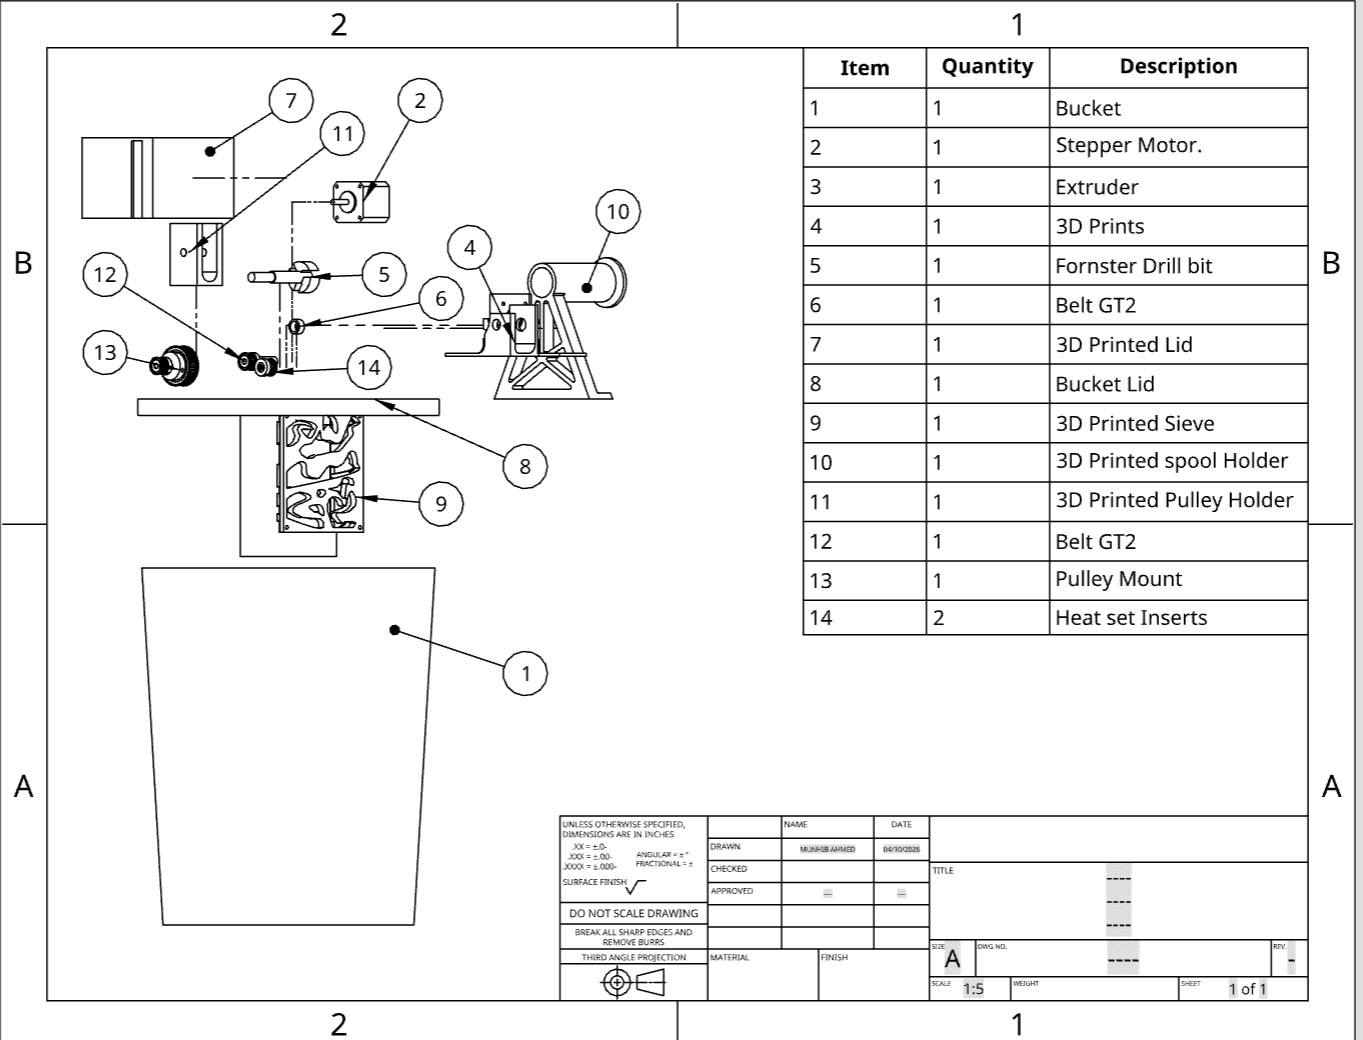
- We designed a single-motor pelletizer: two GT2 belts drive both the feed wheel and a Forstner-bit cutter at a 7:1 ratio, so feed and cut stay mechanically synchronized.
- ESP32 firmware (C++, AccelStepper): a debounced start/stop switch, potentiometer speed control from 6 to 120 RPM, and an IR beam-break sensor that runs the motor only while filament is present.
- We picked the design from 7 concepts with a weighted decision matrix, and produced the Onshape CAD assembly, exploded view, BOM and drilling template.
- I worked across mechanical design and drive ratio, CAD, ESP32 firmware and testing.
The 7:1 drive
Final GT2 design · built, not yet tested
Illustration of the design ratio, not a measurement.
- Cutter : feed wheel
- 7 : 1
On-screen speeds are scaled. Only the 7:1 between the cutter and the feed wheel comes from the design; each belt's ratio to the stepper isn't shown, so neither shaft speed is given.
How we chose the design
| Concept | Weighted score vs baseline |
|---|---|
| Drill-Powered Attachment | +0.55 |
| Razor Cutter | +0.10 |
| Baseline | 0.00 |
| Guillotine Cutter | −0.05 |
| Cam-Driven Scissor | −0.10 |
| Dual-Motor Rotary | −0.10 |
| Solenoid Guillotine | −0.15 |
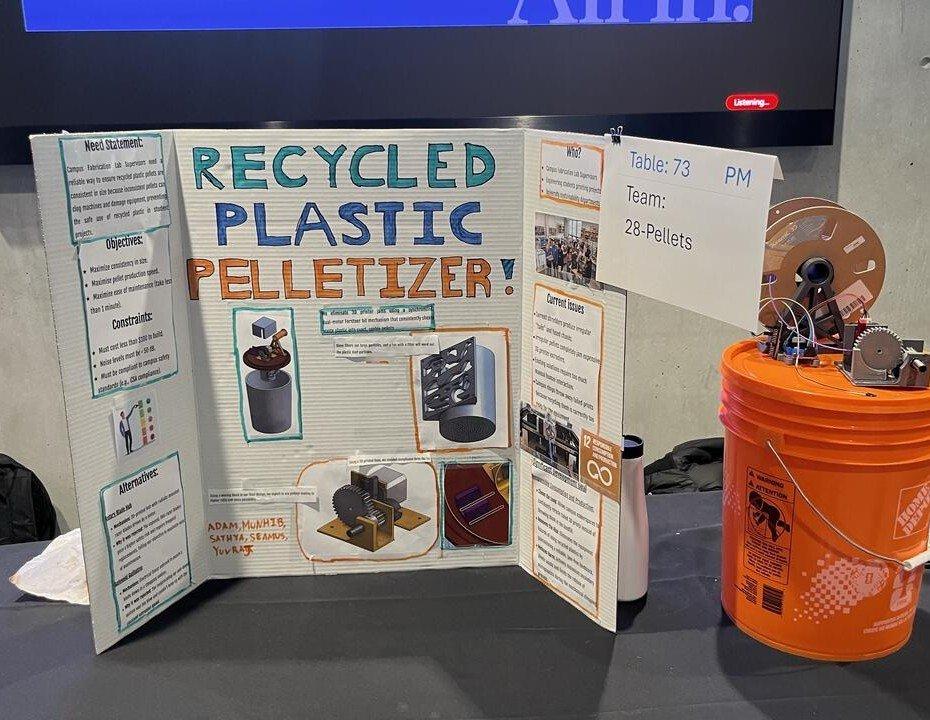
Results, by build
All measurements are from the gear-drive prototype. The final belt-drive design was built but not measured.
Build 1 of 2
Gear-drive prototype
Tested. Every measured result on this page comes from this build.
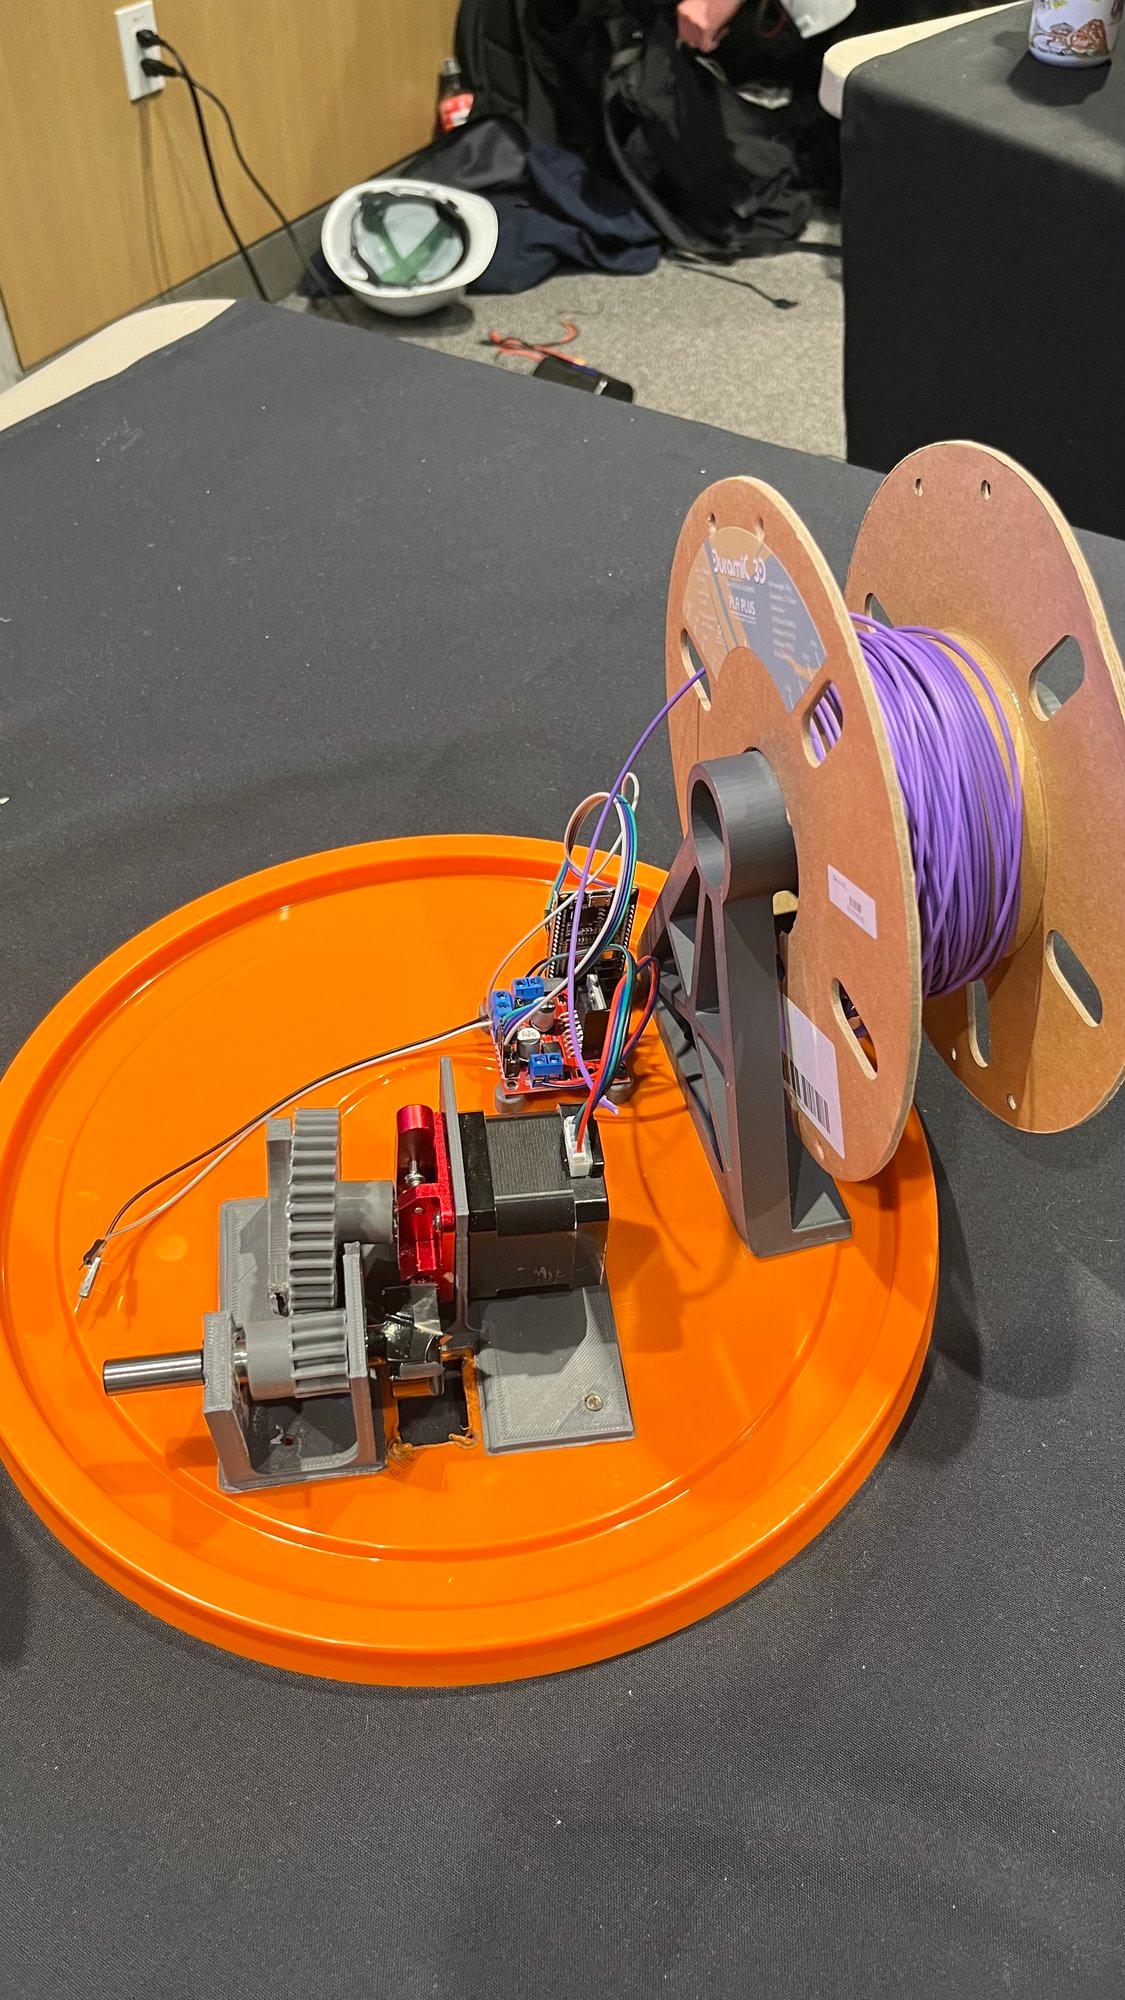
Measured results (gear-drive prototype only)
- 3 mm/s
- Fed a 1 m PLA strand autonomously
- <50 dB
- Noise, by phone sound-meter app
- 12 V
- Input
- 0.5 A
- Idle draw
Gear-drive prototype
- Drive
- 3D-printed spur gears
- Firmware
- Earlier version, no longer available
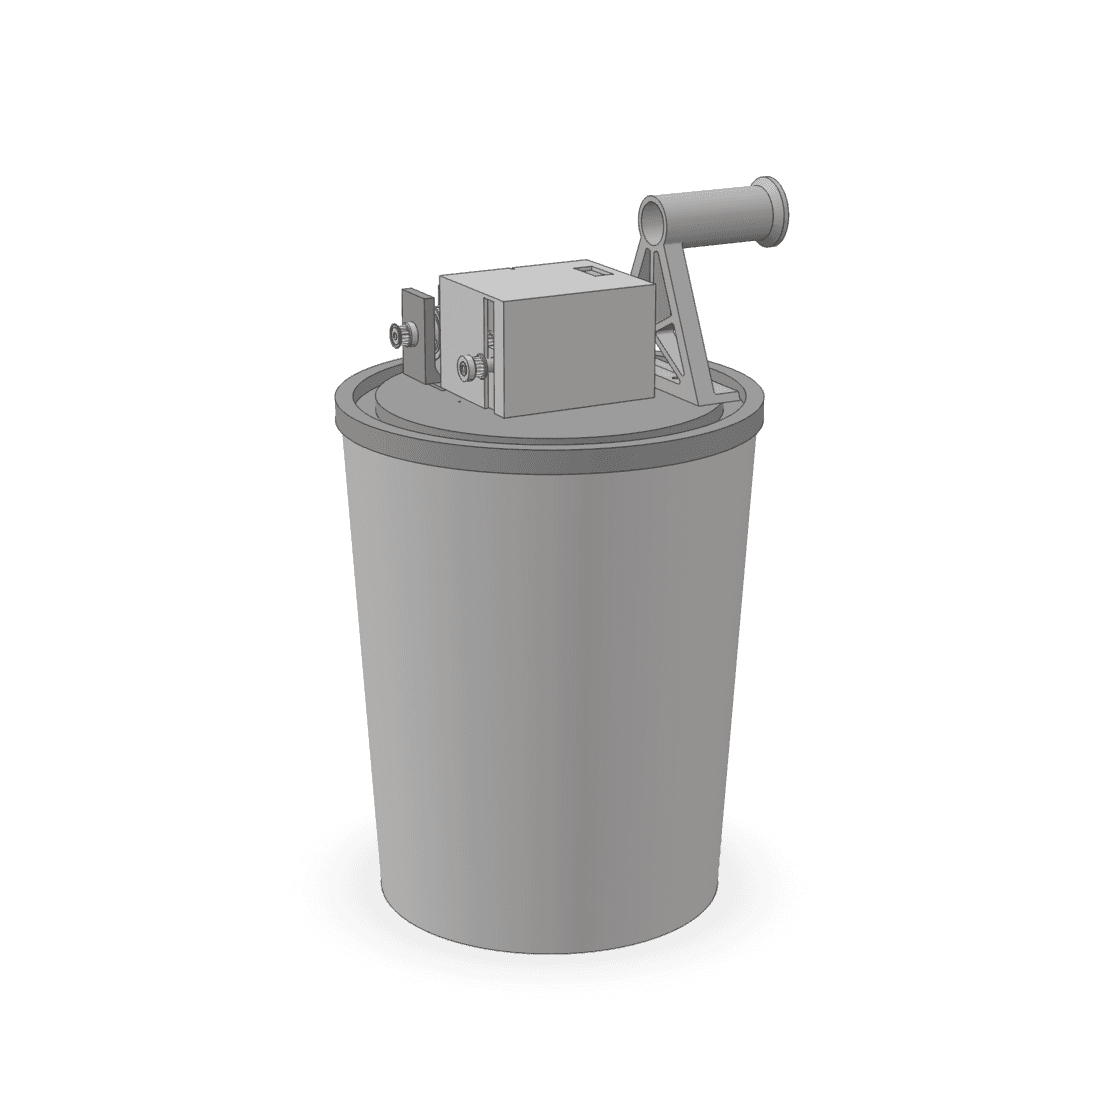
Build 2 of 2
Final GT2 design
Built, and the firmware in the repo ran on it. No measurements were taken on it.
Measured results
None. Built, no measurements taken.
Final GT2 design
- Drive
- Two GT2 belts from one stepper
- Ratio
- 7:1
- Driver
- A4988
- Speed
- 6–120 RPM, set by potentiometer
- Firmware
- ESP32, C++, AccelStepper (in the repo)
What went wrong
- On the gear-drive prototype the first pellets cut cleanly, then the cutter jammed. We traced it to poor chip clearance at the bit.
- All measurements were taken on the gear-drive prototype. None were taken on the final GT2 design, so nothing on this page claims how the final design performs.
Next steps
Film the final build running. It would be the first evidence from that build.
Placeholder
Video not filmed yet: filament feeding in, pellets coming out, and the motor stopping when the filament runs out.