All projects
High school project
VEX Robotics: Crab-Drive Robot
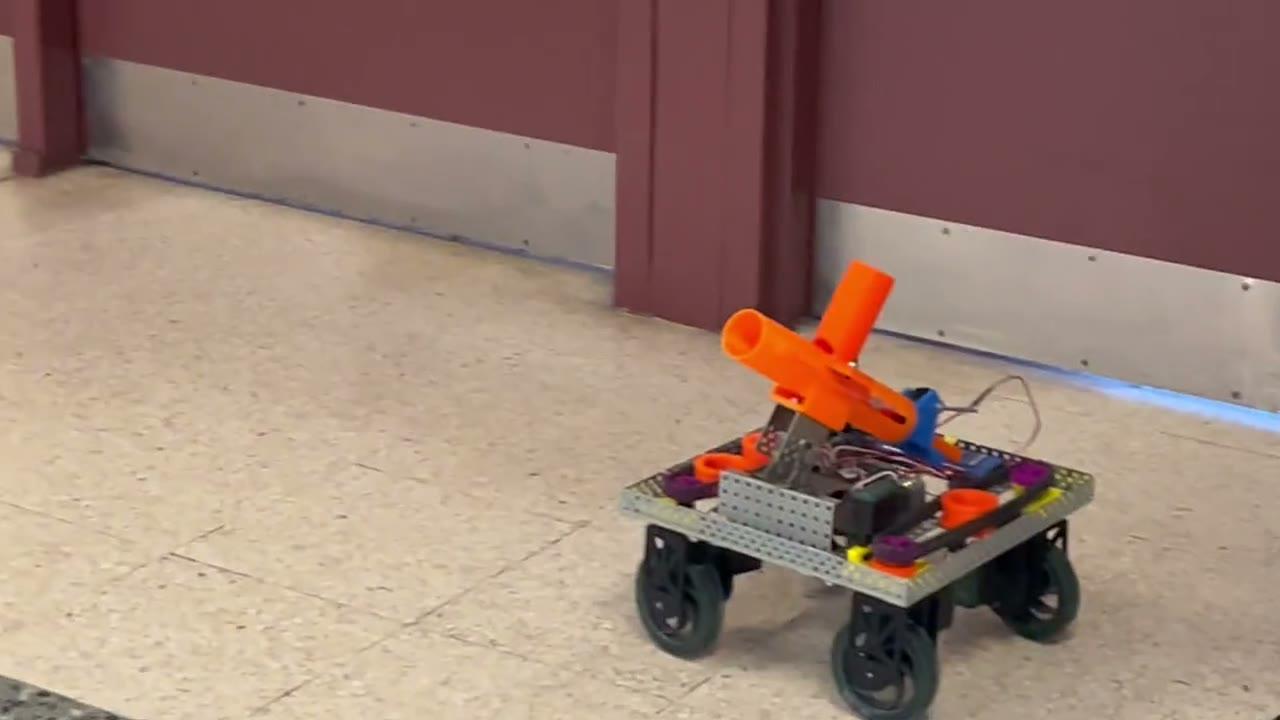
A robot that can strafe sideways — designed, printed, built and coded from raw VEX metal.
Summary
- What it is
- A 6-motor crab-drive robot that can strafe sideways: 4 wheel motors, 2 steering motors
- Context
- High school: robotics course, Iroquois Ridge HS
- Dates
- 2025
- Role
- Design, 3D printing, build and programming of every subsystem
- Tools
- Autodesk Inventor, VEXcode C++, FDM 3D printing, gear trains, chain drive
- Launcher
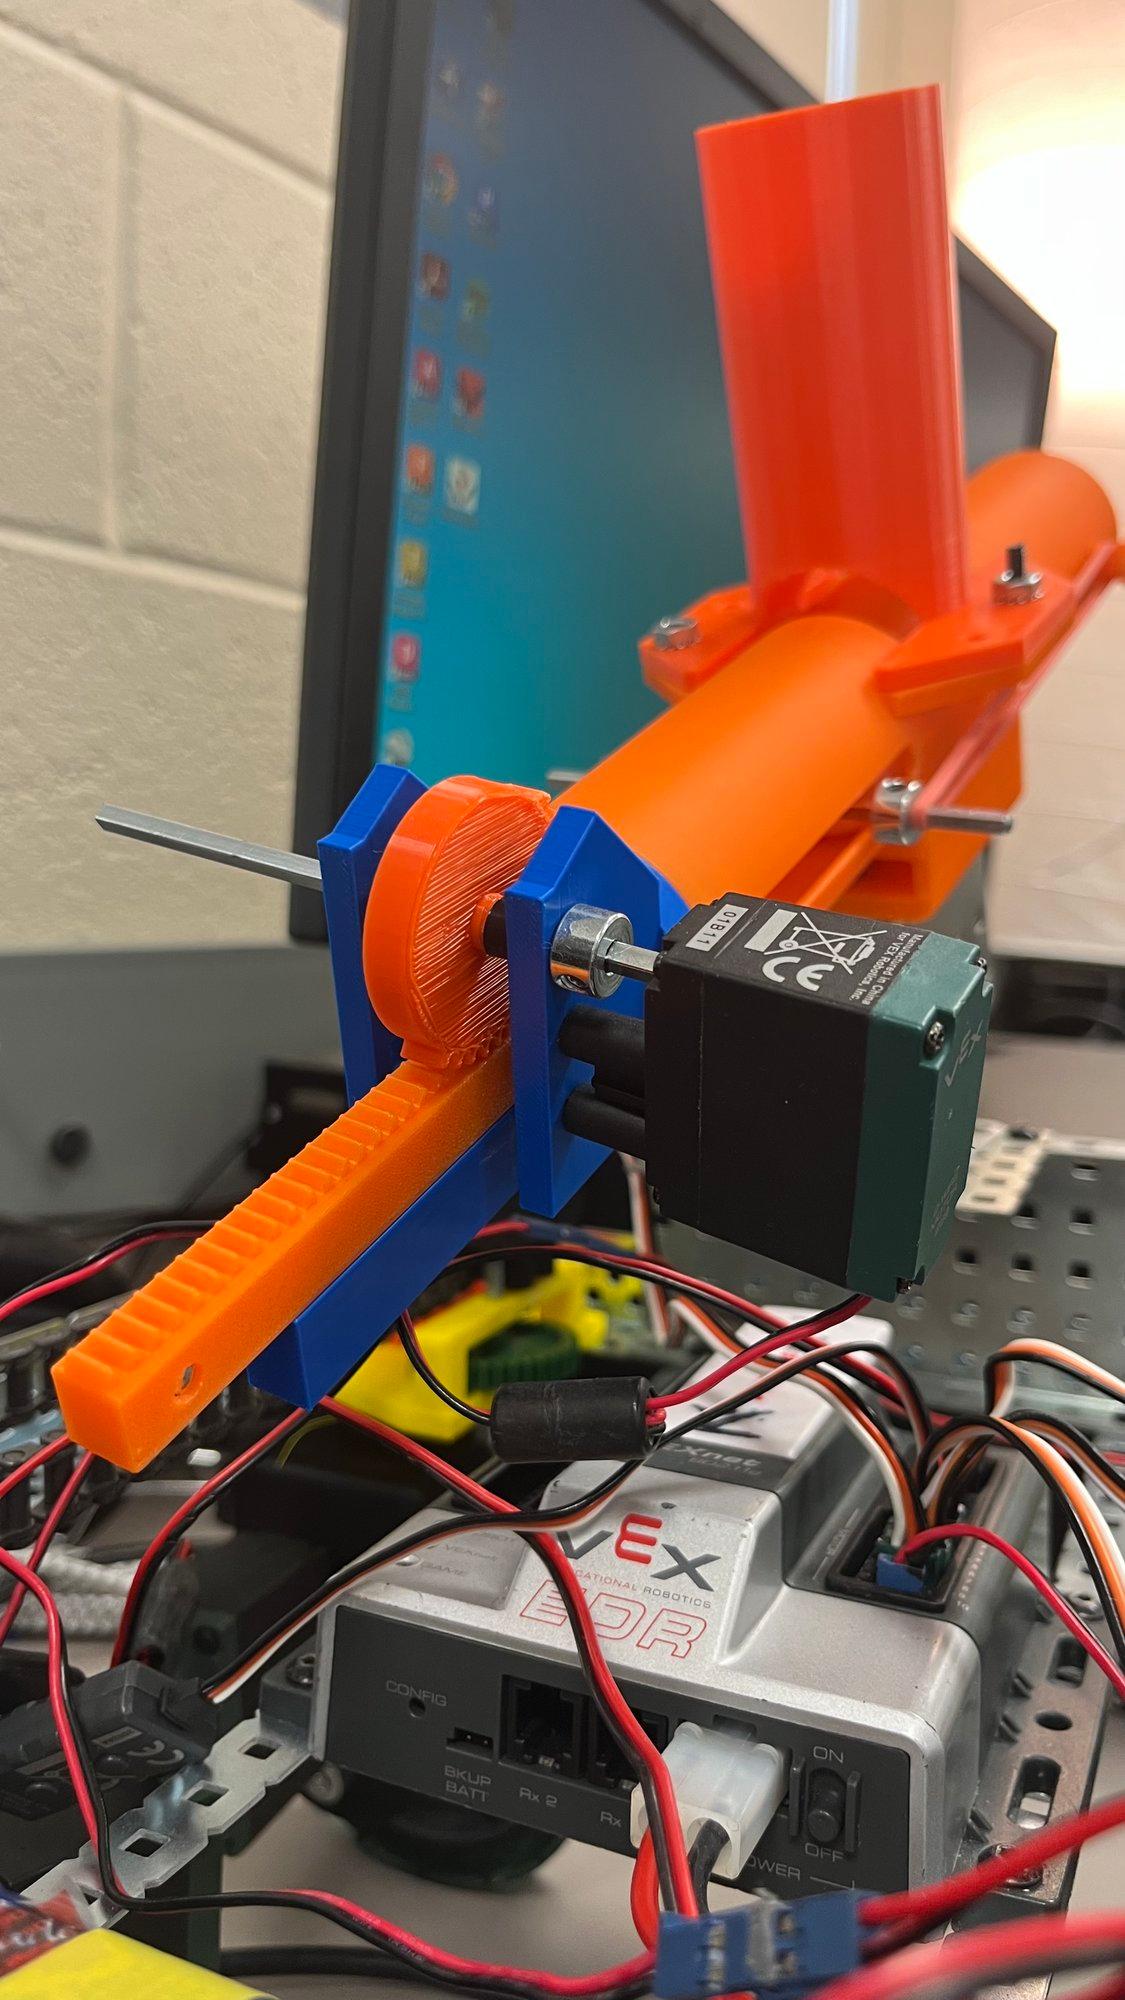
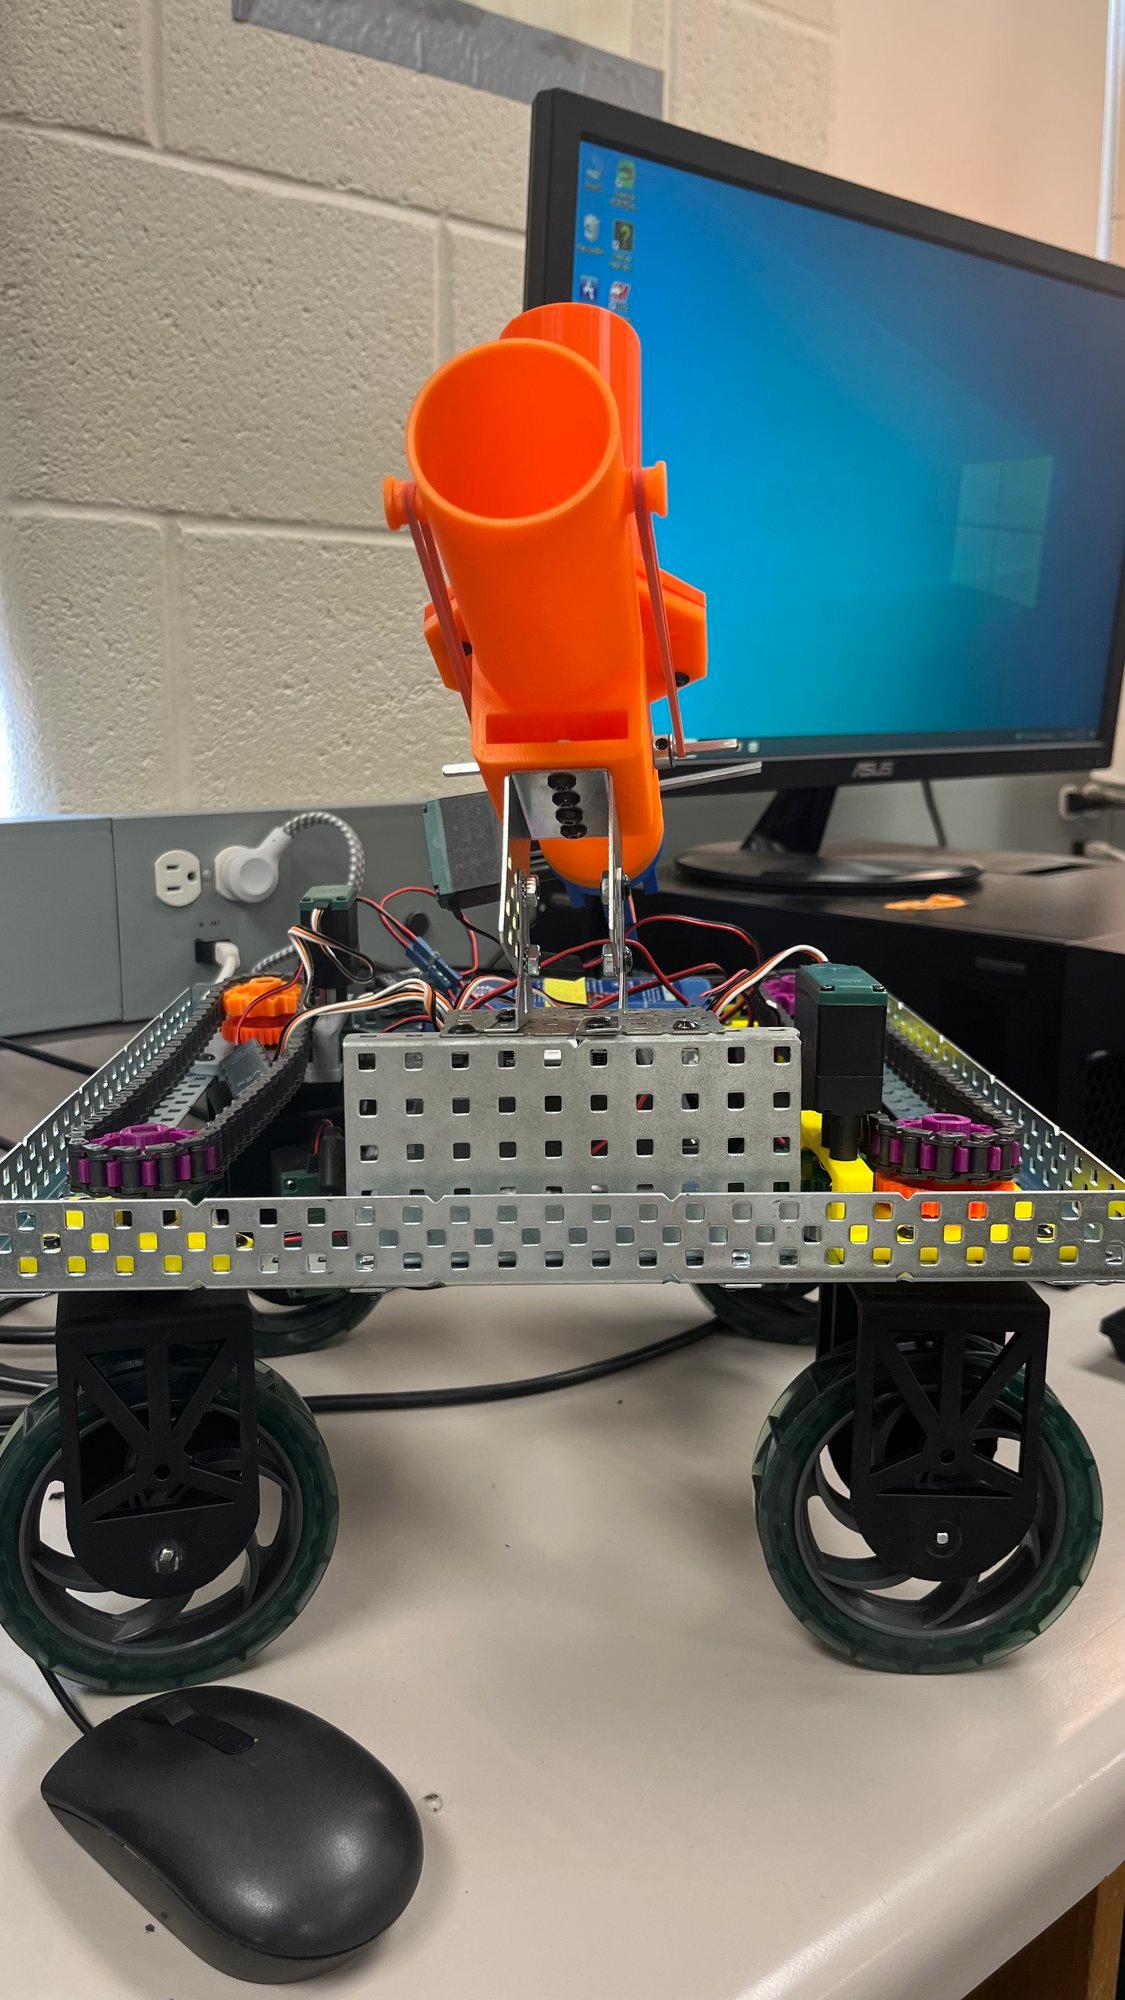
- Motor-driven; fires by releasing a tensioned rubber band
What I built
- I designed the frame, wheel pods and drivetrain assemblies in Autodesk Inventor, then built, 3D-printed, assembled and programmed (VEXcode C++) every subsystem.
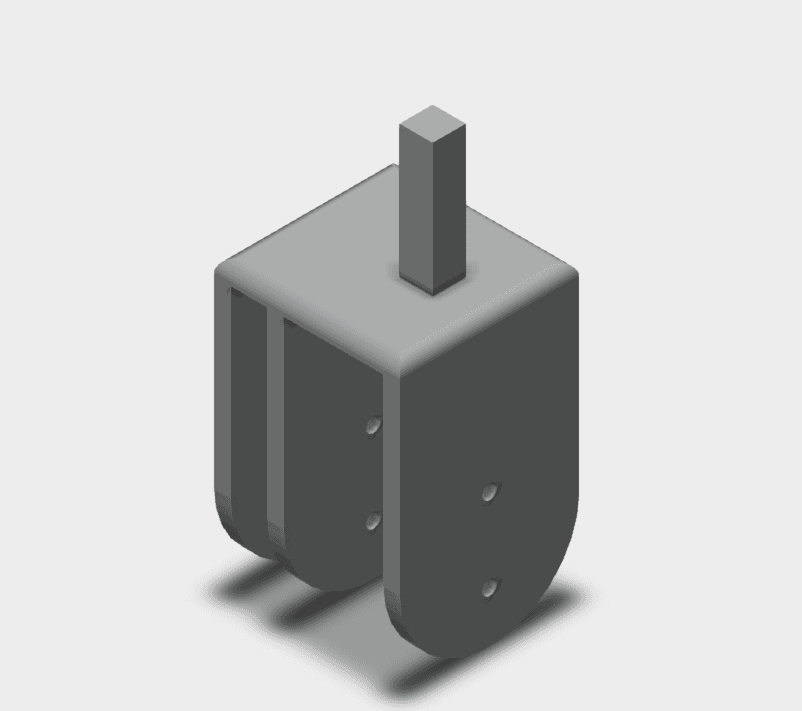
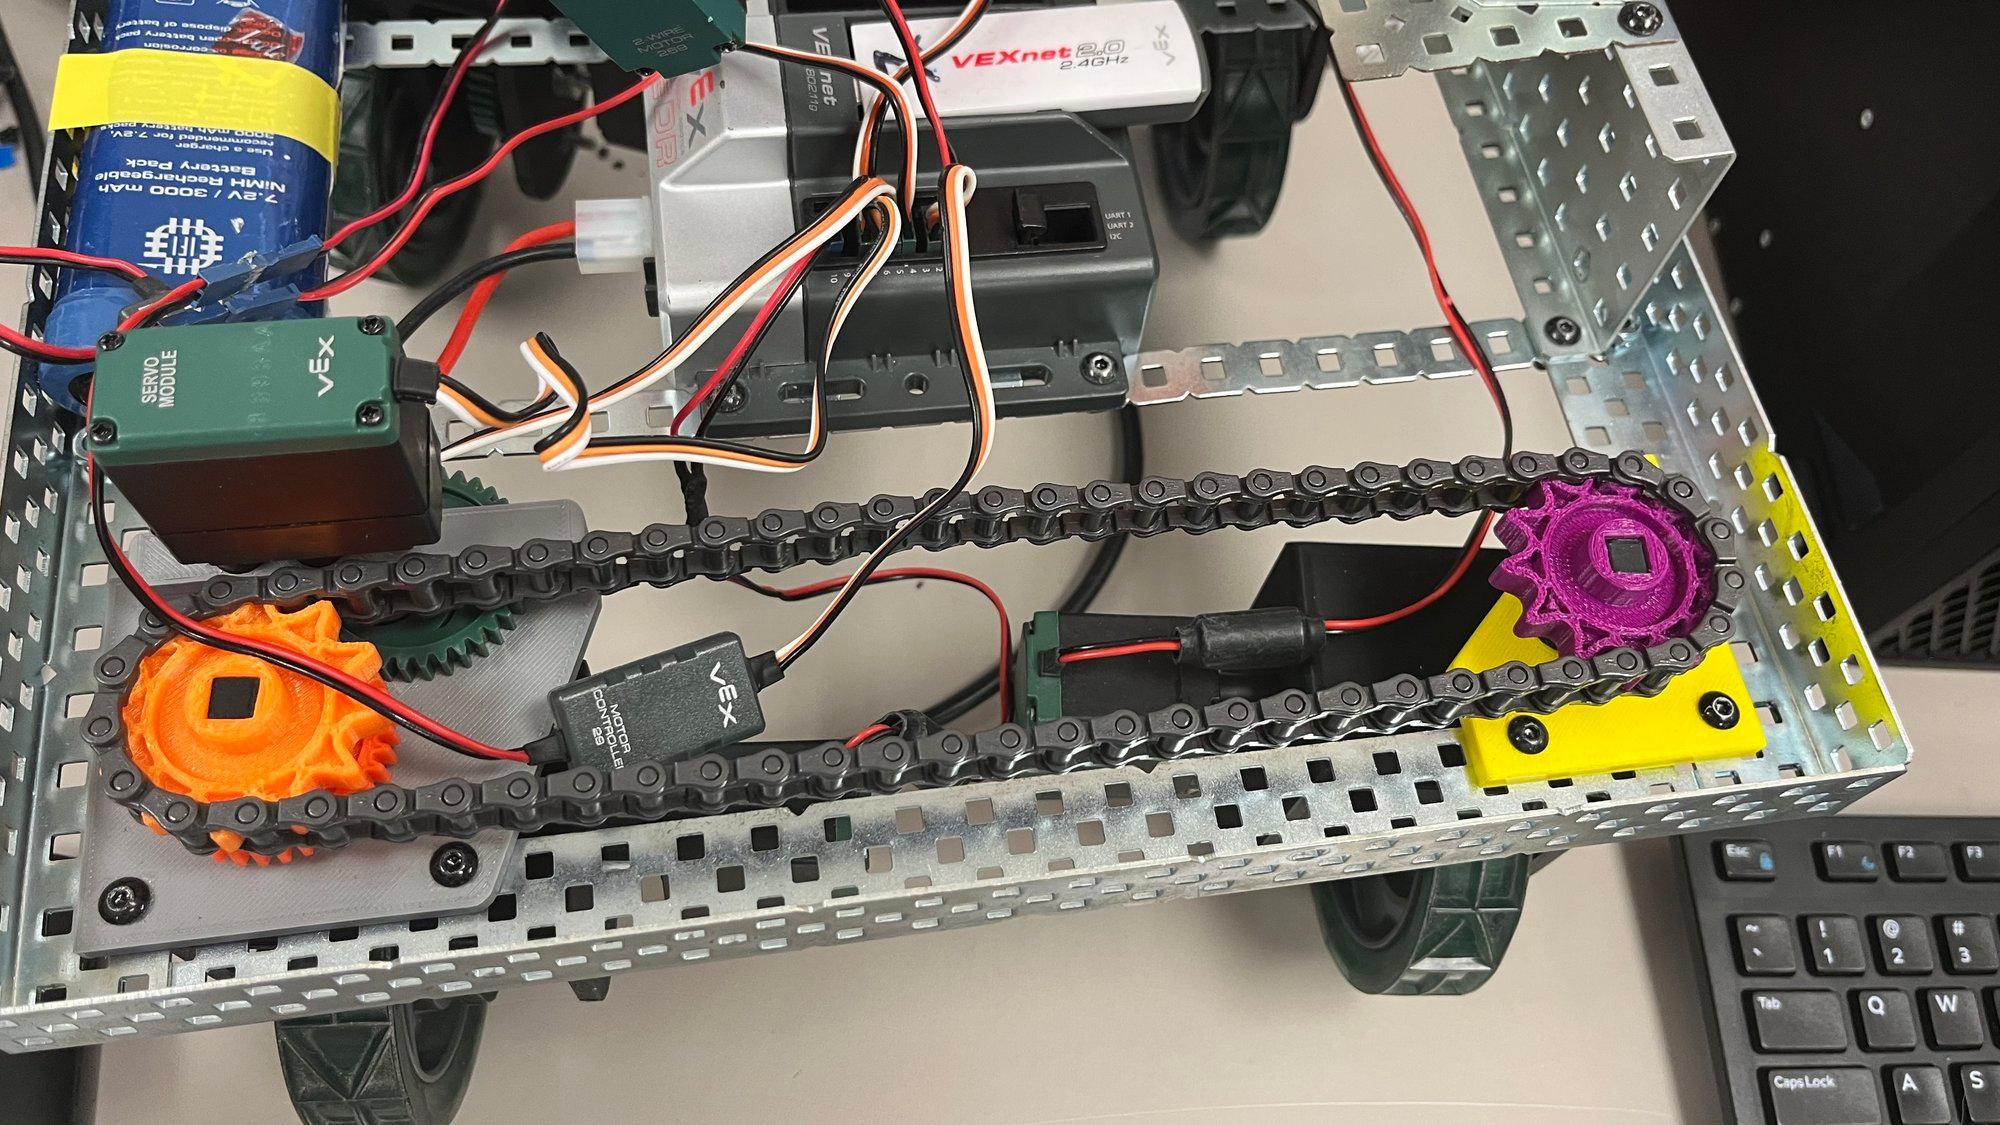
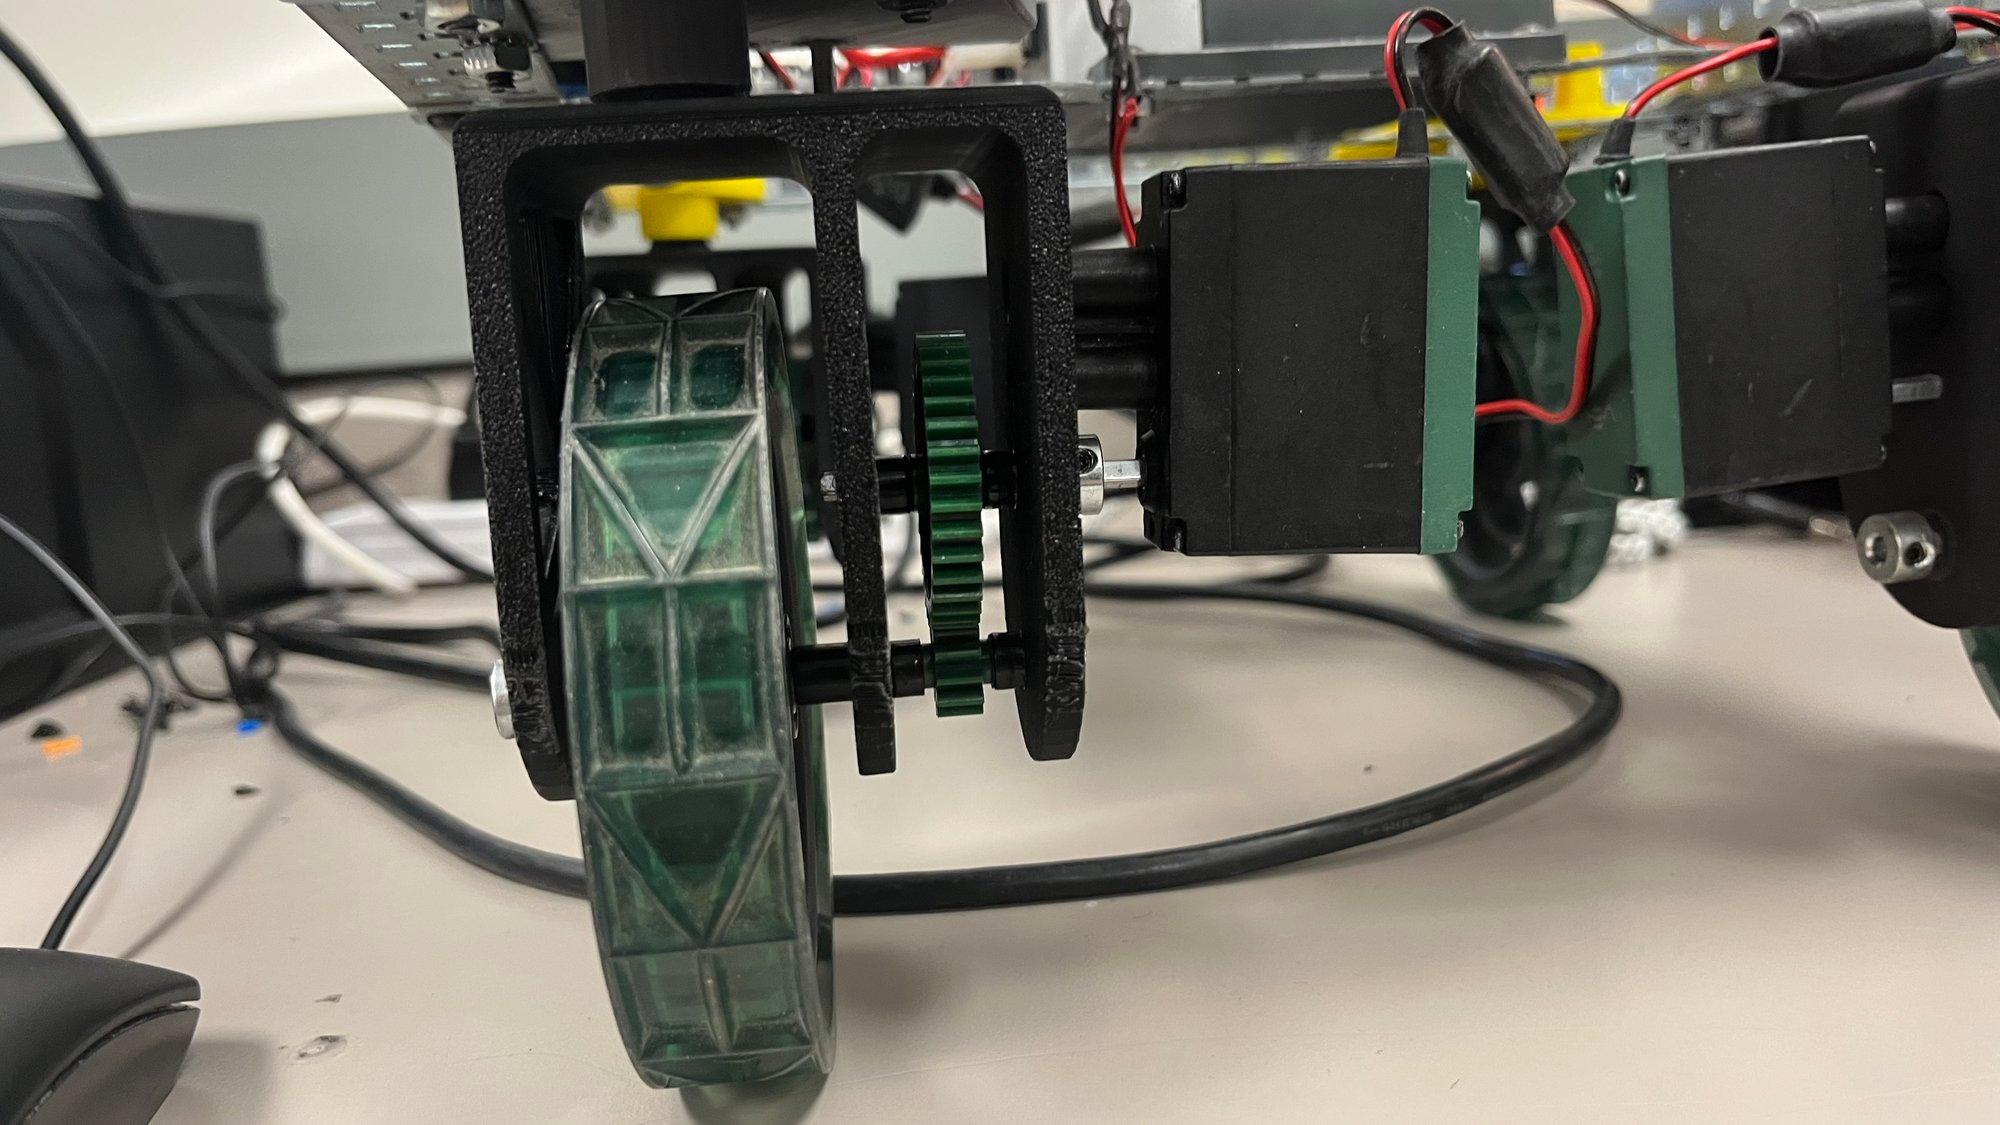
- A 6-motor crab drive: 4 wheel motors (left/right pairs synced in code for tank turns) plus 2 frame-mounted motors that steer the wheel pods through gears and a chain drive so the robot can strafe.
- A motor-driven ping-pong ball launcher that fires on a button press by releasing a tensioned rubber band.
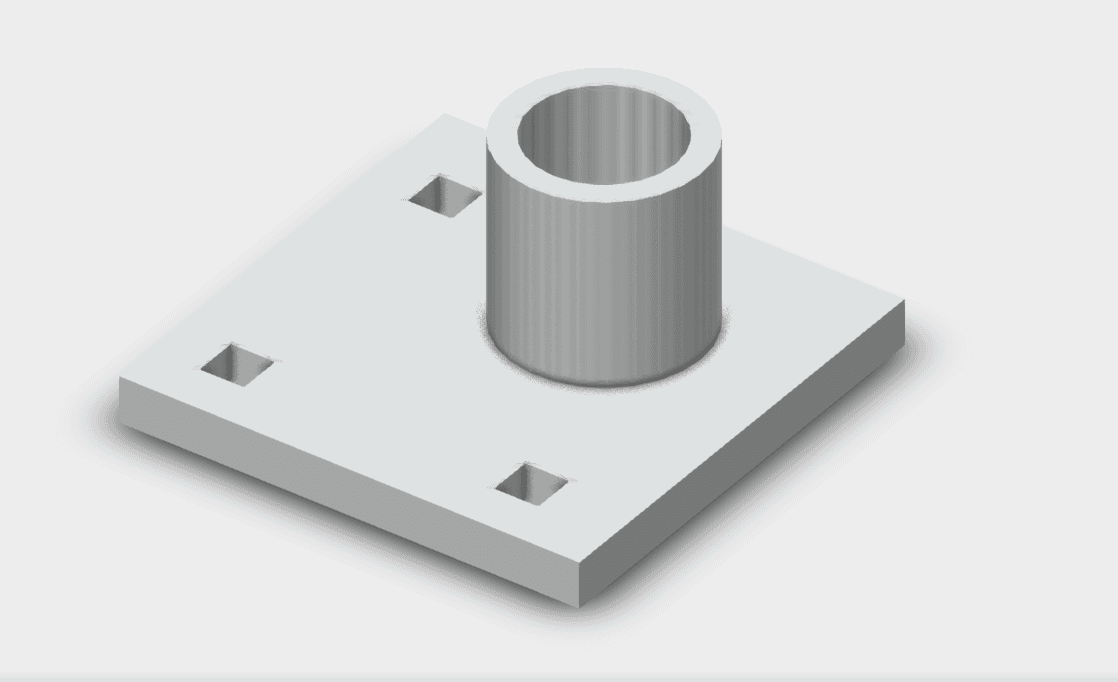
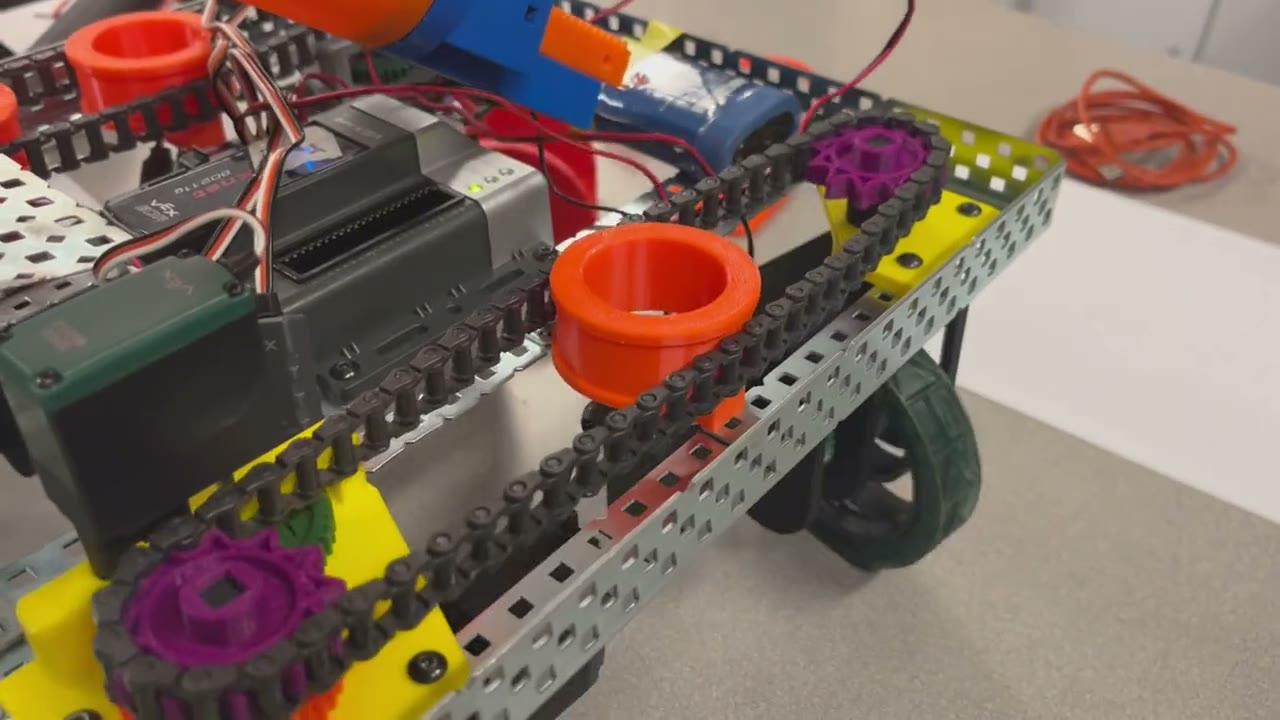
- Ring tensioners, designed and 3D-printed to take up slack in the steering chain.
How it works
- 4 wheel motors drive the robot. The left and right pairs are synced in code for tank turns.
- 2 frame-mounted motors steer the wheel pods through gears and a chain drive. Turning the pods is what lets the robot strafe.
What went wrong
1Wheel pods dropped with one tensioner ring
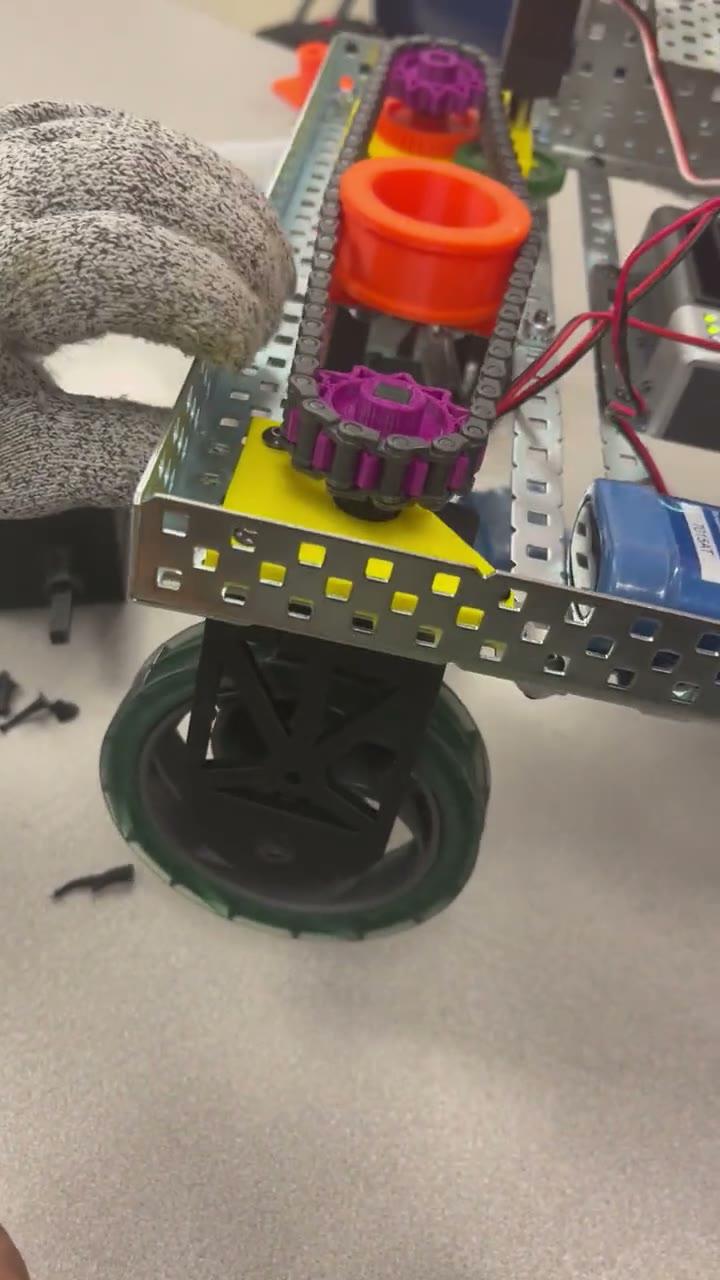
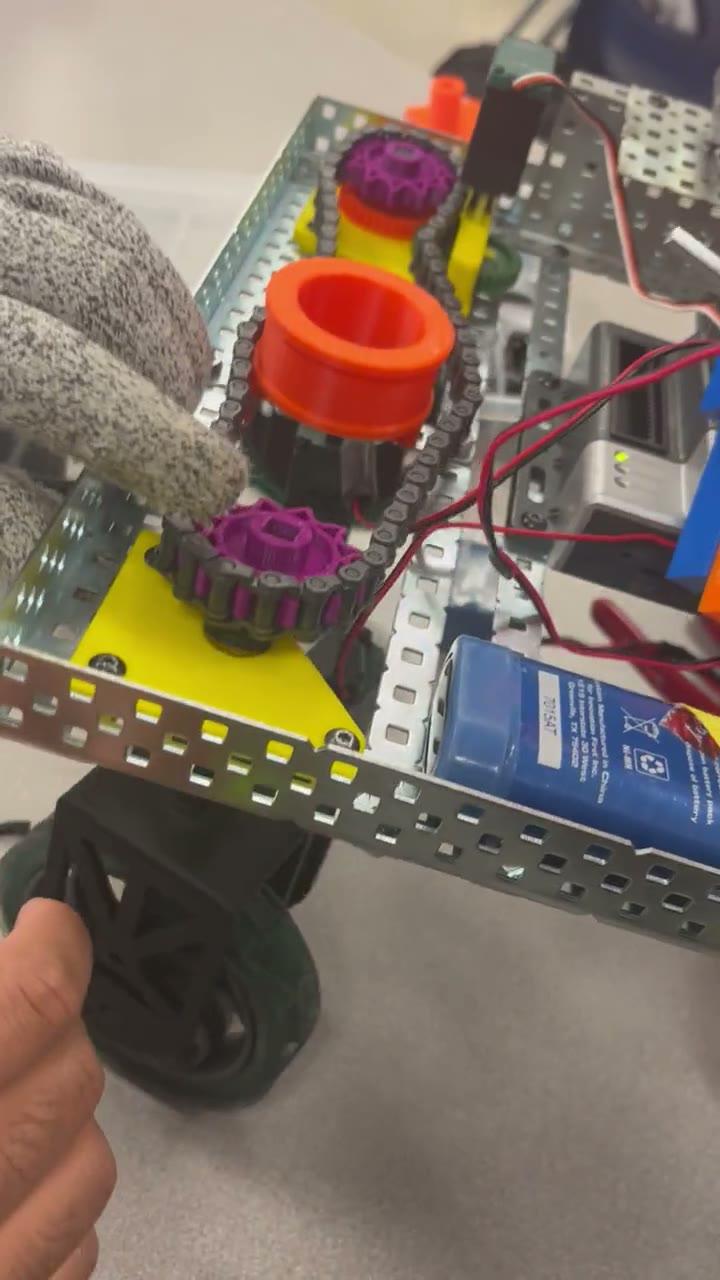
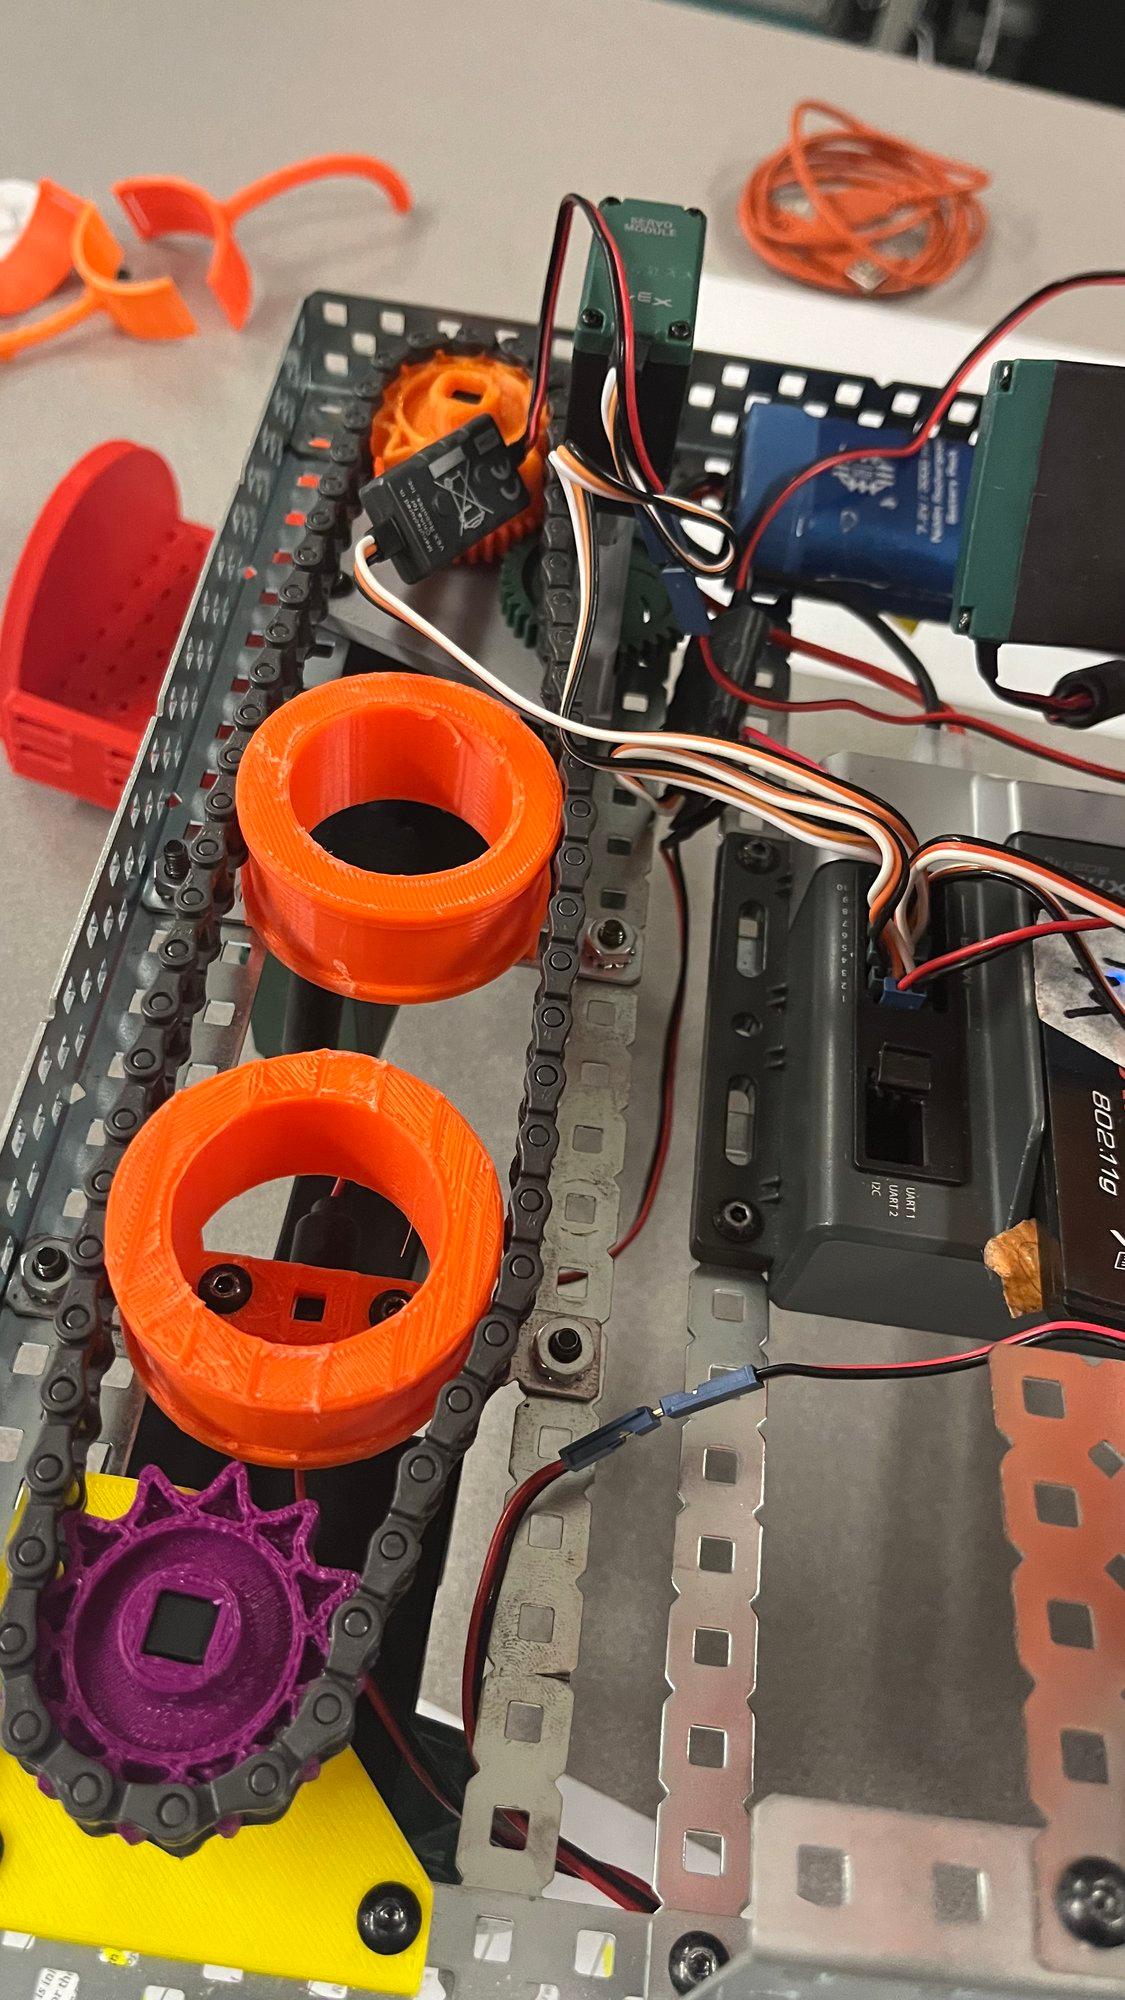
I designed and 3D-printed ring tensioners to take up slack in the steering chain. With one ring the wheel pods still dropped when the robot was lifted, so I added a second. With both, the pods held position and steered together.
One ring, clip 1 of 2
One ring, clip 2 of 2
Two rings
2Launcher walls cracked
The launcher is motor-driven and fires a ping-pong ball on a button press by releasing a tensioned rubber band. Its mechanism includes a rack and pinion.
Early prototypes developed stress fractures. I traced them and thickened the walls in CAD.